I’m Aswin Santhanam, an electronics and embedded systems engineer working across circuit and PCB design, automotive control firmware, maritime communications, and sensor-integrated robotics.
Circuit & PCB designEmbedded C / C++Model-based developmentSIL / HIL validationRF & sensor integration
Selected projects
Research / Prototypes / Robotics
01 / MASTER’S THESIS · TUHH / DLR
Heterogeneous Wireless Communication Architecture in a Modular Research Vessel
Investigated wireless communication beyond Wi-Fi for harsh maritime environments, combining LoRa, Bluetooth Low Energy, and near-field magnetic induction (NFMI).
LoRaBLENFMIRF prototyping
Methods & contribution
Designed a custom NFMI hardware prototype, simulated communication metrics and indoor propagation models, and conducted transmission experiments in a steel enclosure. Relative-attenuation measurements supported evaluating NFMI as an alternative for the tested environment.
02 / MASTER’S PROJECT · TUHH / DLR
Integrated Control, Data Acquisition and Transmission for Autonomous Ships
Integrated control, sensing, and communication into a prototype research-vessel platform for real-time data acquisition and distributed system monitoring.
CANopenEthernetModbus TCP
Engineering contribution
Designed and synchronized multiple communication protocols and bus systems within a common architecture, supporting real-time control and data transmission with potential applications in smart fleet management.
03 / SPP2305 SMART SPHERES · 2023–2024
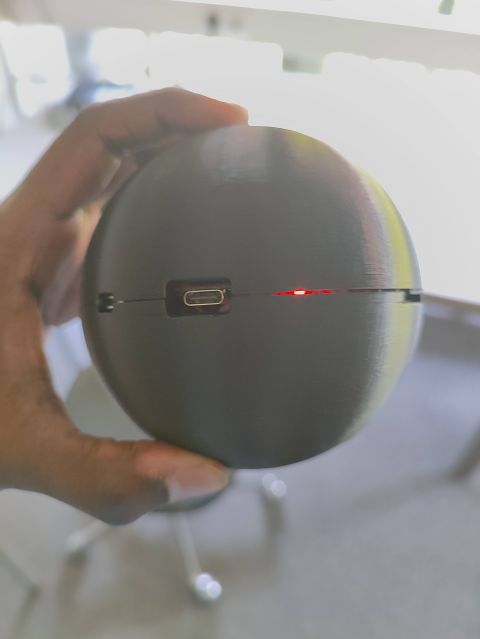
Sensor-integrated Smart Ball prototype.
SPP Ball — sensing motion in 3D
Worked in a four-person team representing TU Hamburg at the SPP Smart Spheres competition in Dresden, developing a ball for autonomous localization, 3D trajectory recording, and wireless data transmission.
Sensor integrationLocalizationWireless telemetry
04 / HUMANITARIAN TECHNOLOGY LABS · 2016
SWACHEK — autonomous room-cleaning robot
Developed an autonomous room-cleaning robot as a student researcher at Amrita’s HuT Labs. The team earned second place in the junior category at OMRG 2016, held at Nanyang Technological University, Singapore.
The project brought together hands-on robotics and embedded systems development for a practical household task.
Low-Power AI Processor for Autonomous Mobile Robots
Co-designed a processor architecture with 64 parallel processing elements for energy-efficient computation in autonomous mobile robots, using VHDL and FPGA design methods.
VHDLFPGAParallel processing
Publication
“A Low Power AI Processor for Autonomous Mobile Robots,” 2019 International Conference on Intelligent Computing and Control Systems (ICCS), May 2019.
06 / ONGOING DEVELOPMENT · AUGUST 2026–PRESENT
FreeRTOS on STM32
Developing real-time applications using task creation, priority scheduling, and inter-task communication, with task-level debugging and timing analysis.
STM32FreeRTOSReal-time firmware
Electronics, circuits & PCB design
Simulation / Layout / Prototyping
Hands-on electronics development spanning circuit simulation, PCB layout, and physical prototypes, connecting board-level design with embedded systems and wireless communication.
01 / CIRCUIT & PCB DESIGN
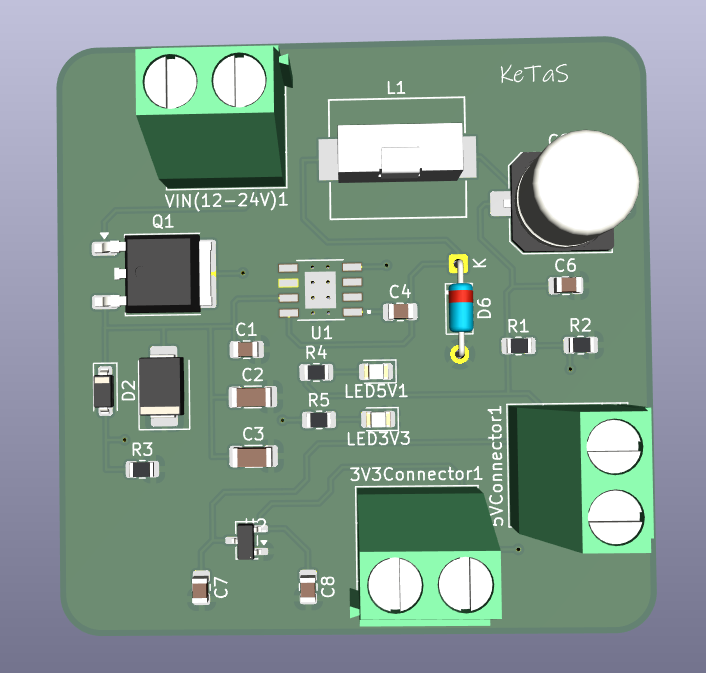
PCB design with a 12–24 V input and connections labelled 5 V and 3.3 V.
From circuit to board
Circuit-level design, simulation, and debugging using NGSpice, LTSpice, and QUCS, alongside PCB design with KiCad and LibrePCB. Board-level work brings component placement, routing, and hardware interfaces together.
Circuit simulationPCB layoutHardware debugging
02 / NFMI HARDWARE PROTOTYPE
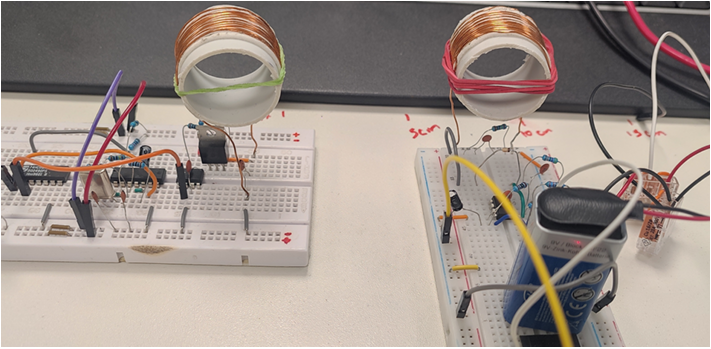
Coil-based near-field magnetic induction prototype on the bench.
Exploring magnetic communication
Designed a custom near-field magnetic induction (NFMI) hardware prototype for the master’s thesis on wireless communication in a modular research vessel. The work connected circuit prototyping with transmission experiments in a steel enclosure.
The bench setup shows the wound coils and breadboard circuits used to explore the communication approach.
NFMICoil-based circuitsExperimental validation
Research context
Evaluated NFMI alongside LoRa and BLE for harsh maritime environments, using communication modelling and relative-attenuation measurements. View the master’s thesis project.
Professional experience
Industry & applied research
Apr 2026–present Remote
Electronic Engineer / AI Trainer · Micro1
Circuit-level design, simulation, and debugging using NGSpice, LTSpice, QUCS, and KiCad/LibrePCB.
Nov 2023–Mar 2026 Hamburg, Germany
Working Student, Maritime Energy Systems · DLR
Integrated embedded platforms for sensor acquisition and distributed monitoring; developed wireless communication prototypes and a motor test bench. Completed the master’s project and thesis in maritime embedded systems.
Dec 2022–Aug 2023 Hamburg, Germany
Working Student, Model Based System Design · Bertrandt
Developed SysML models in Cameo Systems Modeler for aircraft architectures and requirements-driven systems engineering.
Owned ApbMi, CDP, and ETRS functions across SGM vehicle programs, with responsibilities from requirements through implementation, testing, and release. Developed automotive control software using ASCET and Embedded C within an AUTOSAR-based architecture; performed SIL/HIL validation with Labcar and coordinated supplier and international testing activities.
Recognition at Bosch
Ownership & software quality
Robert Bosch · March 2022
Quality Champ
Recognized for coordinating embedded firmware releases with third-party suppliers and aligning supplier, Bosch, and customer requirements.
Robert Bosch · Early-career recognition
Bright Beginning
Recognized for rapidly taking ownership of three automotive control functions and developing capability across requirements, implementation, and testing.
About me
Curiosity built into a career.
From a school science-fair hydraulic power plant to automotive firmware and maritime research, I’ve learned by building systems and understanding how they work.
At Amrita’s Humanitarian Technology Labs, I developed a lasting interest in robotics and embedded systems. Bosch gave me responsibility for safety-critical automotive functions; my master’s at TU Hamburg extended that foundation into integrated circuits and wireless communications.
My long-term goal is to design smart robotics and embedded systems that benefit people. I bring circuit and PCB design, hands-on prototyping, disciplined validation, and experience connecting teams across hardware, software, and testing.
M.Sc. Microelectronics and Microsystems Technical University of Hamburg · November 2025 Minor: Embedded Systems
B.Tech. Electronics and Communications Engineering Amrita Vishwa Vidyapeetham, Kollam · December 2018
Technical expertise
Tools & methods
Firmware & automotive
Embedded C / C++ · Python FreeRTOS · Bare-metal systems ASCET · MATLAB / Simulink AUTOSAR · ASPICE · DOORS SIL / HIL · Labcar · CANoe
Hardware & communications
STM32 · ESP32 · Raspberry Pi CAN / CAN-FD / CANopen Ethernet · Modbus TCP · Mavlink SPI · I²C · UART LoRa · BLE · NFMI